Just like a finely tuned instrument, your drone’s flight performance depends on precise PID adjustments. In Betaflight, PID tuning controls how strongly your flight controller reacts to movement, error, and stick input. When you tune carefully, your quad feels smoother, sharper, and more predictable. When you rush the process, you can create oscillations, hot motors, propwash, bounceback, or a twitchy flight feel. This guide walks you through Betaflight PID tuning in a safe, step-by-step way so you can improve response without turning your setup into chaos.
Quick Answer
To tune Betaflight PID settings, start with a clean mechanical build, default filters, and safe test flights. Adjust P gains first, balance D gains to control bounceback and oscillation, then use I gain, Feedforward, Anti Gravity, rates, and expo to refine drift control, throttle stability, and stick feel.
Key Takeaways
- Tune only after fixing mechanical problems such as bent props, loose screws, bad soft mounting, or frame vibration.
- Change one setting at a time so you can clearly see what improved or worsened.
- P gain affects tracking and sharpness, D gain helps control overshoot, and I gain corrects drift over time.
- Hot motors, fast oscillations, and harsh motor noise usually mean your tune or filters need attention.
- Use short test flights, careful notes, and gradual changes instead of chasing a perfect tune in one session.
At a Glance
| Time Required | 30 to 90 minutes for basic tuning; longer if you review Blackbox logs |
| Difficulty | Intermediate, with beginner-friendly steps if you use small changes |
| Tools Needed | Betaflight Configurator, charged packs, fresh props, open flying area, optional Blackbox logs |
| Cost | Usually free, aside from spare propellers and normal battery use |
What’s Tuning?
When you tune your drone, you’re adjusting the PID gains in the flight controller software to improve its flight performance. Tuning is the process of shaping how the quad reacts when it tilts, rotates, drifts, accelerates, or follows your stick commands. A well-tuned drone feels locked in, smooth, and predictable. It minimizes oscillations, wobbles, drift, bounceback, and propwash during normal and aggressive flying.
Betaflight uses PID control to help the flight controller compare the movement you requested with what the gyro actually sees. The controller then tells the motors how to correct the difference. P, I, and D each handle a different part of that correction. Feedforward, Anti Gravity, filtering, rates, and expo then shape the feel even more.
Using tools like Blackbox during tuning helps you analyze flight data more effectively. Logs can show noise, overshoot, propwash, and motor activity that you may miss by eye. Even without logs, you can still make meaningful improvements by using controlled test flights, small changes, and careful motor checks.
The main goal is to create smooth cruising, clean flips and rolls, reduced propwash, and a confident feel during fast throttle changes. Tuning can still be complex, even for experienced pilots, because each adjustment affects the others. For that reason, you should always move slowly, test often, and monitor motor temperatures to prevent overheating.
Warning: Remove propellers before connecting your quad to Betaflight Configurator for setup changes. Only install props when you are outside and ready for a controlled test flight.
Tuning Goals and Rules
When tuning your drone, your primary goal is to achieve smooth flight characteristics without creating unsafe behavior. You want the quad to track stick inputs cleanly, resist drift, recover from maneuvers without bounceback, and handle throttle changes without wobble. It is essential to avoid crashes during tuning because bent props, damaged arms, loose stacks, or shifted components can ruin your results.
Good tuning follows a few simple rules. Use a mechanically sound quad, fly in safe conditions, make one change at a time, and keep notes. Avoid large jumps in settings unless you clearly understand the risk. If a change creates hot motors, fast buzzing, or unstable behavior, land quickly and step back.
Smooth Flight Characteristics
To achieve smooth flight characteristics in Betaflight, you must tune your PID settings for a locked-in feel during flight. Your primary goal is smooth cruising without oscillations, wobbles, or drifting. Start by understanding the P value. A higher P value can improve tracking and response, but too much P can create fast oscillations and instability.
It’s essential to eliminate bounceback during flips or rolls so your drone stops cleanly after a maneuver. D gain helps control that overshoot, but too much D can heat the motors and amplify noise. To minimize propwash and wobble during extreme actions, fine-tune your PID settings incrementally instead of making dramatic changes.
Always monitor motor temperature after each flight. Warm motors are normal, but motors that feel too hot to touch comfortably can point to excessive D gain, too much filtering reduction, mechanical noise, damaged props, or a rough tune. Using fresh, balanced propellers also contributes to stable performance. Small adjustments often create the biggest improvements in your flight experience.
Avoid Crashes During Tuning
A successful tuning session requires careful attention to safety. Start by using new, balanced propellers for stable flight. If you usually fly with a GoPro, action camera, battery strap pad, GPS, buzzer, or other gear, include that during tuning so the weight and balance match your normal setup.
Make small changes to the PID controller settings one at a time. This helps you monitor how each adjustment affects flight dynamics. After each flight, check for hot motors, harsh motor sound, twitching, and visible oscillation. Any of these can signal that your current PID settings, filters, or mechanical setup need correction.
Always conduct tuning in an open area without obstacles. Avoid flying near people, pets, vehicles, buildings, or power lines. Use short test flights at first. A 20- to 30-second hover, punch-out, turn, or roll test can reveal enough information without pushing the quad too hard.
Pro Tip: Keep a simple tuning note on your phone. Write down the setting you changed, the amount changed, flight feel, motor temperature, and whether the change improved or worsened the quad.
Basic Configurations and Filters
To set up your flight controller effectively, start with a solid mechanical build. Use rubber grommets for vibration dampening, secure the flight controller properly, and check that no wire, zip tie, camera mount, or loose part touches the gyro area. A noisy build is harder to tune because the flight controller must fight vibration before it can control movement.
Flash a stable Betaflight firmware version that fits your flight controller, then begin with default PID and filter settings. Defaults give you a safe foundation. After you configure receiver settings, arming, modes, motor direction, failsafe, and battery settings, conduct a test flight before making filter changes.
[Amazon Products Picked for You]
【Real FPV Training Feel】The FLYDrone S8 Pro simulator controller is designed for beginner FPV pilots who want to practice before flying a real drone. The Mode 2 layout and non-centering throttle help build throttle control, stick coordination, and real FPV muscle memory in simulator training
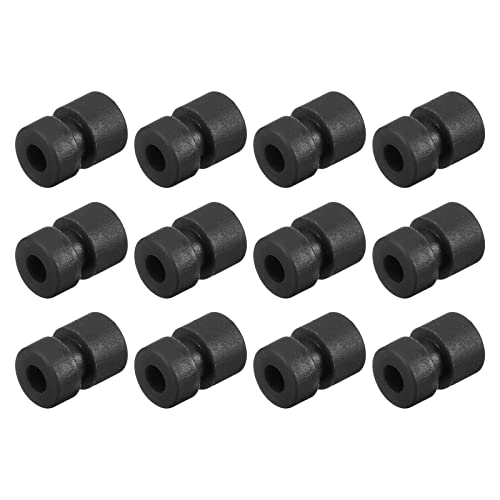
The Rubber Vibration Damper Balls mount rubber balls for the flight controller RC drone. These rubber damper balls can effectively help to reduce the sensitivity of the flight controller and reduce the vibration of aerial aircraft.

[Effective Vibration Dampening]: Designed to "soft mount" your F4 or F7 flight controller, these rubber balls effectively isolate high-frequency vibrations generated by motors. This helps filter out mechanical noise, ensuring the gyro sensor operates smoothly and significantly reduces the "jello effect" in your FPV video feed.
Essential Flight Controller Setup
While setting up your flight controller, it’s crucial to start with a strong foundation that supports consistent performance. Begin by using a flight controller stack with rubber grommets for effective vibration dampening. Secure the stack firmly without crushing the soft mounts. Check that the stack is level, the frame screws are tight, and the arms do not flex or shift under load.
Flash the latest suitable Betaflight firmware for your board and load the default PID and filter settings to create a stable baseline. Confirm you select the correct receiver or RC link preset when it matches your quadcopter configuration. Presets can save time, but you should still review each change before applying it.
Conduct initial test flights with conservative defaults. These settings usually provide smooth cruising characteristics on a healthy build. For very clean builds, some pilots reduce filtering later to improve response, but do not rush this step. Keeping enough filtering helps prevent gyro noise from reaching the PID loop and creating hot motors or unstable flight.
Default PID and Filter Settings
Before diving into advanced tuning, make sure you’ve established a solid baseline with the default PID and filter settings in Betaflight. Start with a flight controller stack featuring rubber grommets for vibration dampening and secure it with suitable hardware for stability. Flash your chosen Betaflight firmware and load the default PID and filter settings, which are usually conservative enough for safe first flights.
Here are key points to remember:
- Use defaults as your starting point instead of copying random tune values from another build.
- Only reduce filtering after confirming the quad is mechanically clean and motors stay cool.
- Keep enough gyro filtering enabled to reduce the risk of noise-related instability.
- Test fly the drone with default settings before making any filter adjustments.
- Use Blackbox logs when available for detailed analysis of noise, overshoot, and propwash.
- Evaluate performance by sound, feel, video movement, and motor temperature.
This approach establishes a strong foundation for your tuning journey and helps you avoid chasing problems caused by loose hardware or damaged props.
Test Flight Adjustments
After establishing a solid baseline with default settings, you can begin refining your drone’s performance through test flight adjustments. Start with a basic configuration that includes a flight controller stack with proper vibration dampening. Conduct an initial test flight to evaluate stability and performance, focusing on how your stick inputs affect response.
Use repeatable test movements. Try a steady hover, smooth forward cruise, short punch-out, quick roll, quick flip, hard turn, and controlled descent through your own propwash. If you notice overshoot or oscillation, adjust the PD ratio by modifying P and D values incrementally.
For cleaner builds, you may later consider reducing some filtering, but keep stability and motor temperature as your priority. Monitor motor temperatures closely. If they rise excessively, reassess your settings, props, frame condition, and filter choices. Always make adjustments gradually to avoid introducing instability into your drone’s flight characteristics.
Note: A bad tune is not always a software problem. Bent propellers, loose arms, worn motors, soft frame plates, or an over-tightened flight controller can all create symptoms that look like PID issues.
Finding P/D Balance and Maximizing PID Gains
To achieve an ideal P/D balance in your Betaflight setup, start by adjusting the P gain from a safe baseline, then gradually increase it until the quad tracks better without developing oscillations. If oscillations appear, reduce the value until the flight feels stable again. Many pilots use a conservative safety margin below the point where oscillation begins.
P gain helps the drone correct movement error quickly. Too little P can feel loose, lazy, or imprecise. Too much P can make the quad shake, buzz, or overcorrect. D gain helps slow that correction near the target, reducing overshoot and bounceback. Too little D can make the quad rebound after flips or rolls. Too much D can create hot motors and noisy flight.
Use these guidelines to maximize your PID gains effectively:
- Isolate P and D terms as much as practical by using the PID slider system in Betaflight Configurator.
- Disable or reduce extra response-shaping features temporarily if they hide what P and D are doing.
- Adjust D gains after stabilizing P gains to minimize oscillations during rapid maneuvers.
- Monitor motor temperatures to prevent overheating while tuning.
- Incrementally increase the Master Multiplier slider when using sliders, then test briefly after each adjustment.
- Back down from any setting that causes hot motors, visible oscillation, harsh motor sound, or twitching.
This methodical approach helps you maintain a balanced relationship between the P term and D term, improving your drone’s flight characteristics without sacrificing reliability.
Tuning D Gains and I Gains
Once you’ve stabilized your P gains, focus on tuning the D gains to reduce overshoot and oscillations during quick maneuvers. Gradually adjust D gains while monitoring motor temperatures to prevent overheating. A careful balance is essential. Too much D gain can heat motors and amplify gyro noise, while too little D gain may lead to bounceback or excessive oscillation during aggressive maneuvers.
After achieving stable P and D settings, introduce or refine I gains. These gains correct drift and help the quad hold attitude against wind, battery sag, and small balance changes. Keep them balanced so the quad feels stable without becoming sluggish. Too little I can allow drift. Too much I can create slow overshoot, delayed correction, or a heavy feel.
| Gain Type | Adjustment Focus |
|---|---|
| D Gains | Reduce oscillation |
| I Gains | Correct drift |
| Stability | Achieve locked-in feel |
| Testing | Continuous minor tweaks |
Continuous testing and minor adjustments based on flight characteristics are crucial for optimizing performance. If the drone slowly leans, wanders, or struggles to hold its angle, review I gain and Anti Gravity. If it snaps back too hard after a roll, review D gain, Feedforward, and I Term Relax.
[Amazon Products Picked for You]

Durability: Impact-resistant and adaptable to various environments.

Multifunction: Our M5 M3 quick release wrench tool is designed for fpv propeller tighten or releasing M3 M5 hex nuts on fpv motors.

Introducing the perfect field tool that you will carry with you everywhere.Combining the three most common tools into one tiny and extremely handle little trifecta. Two 8mm prop nut sockets on opposing ends of silky smooth and robust redesigned one-way bearing system enable for quick and smooth prop changes. The silver side is for loosening and black side tightening. These 8mm hex sockets are Accompanied by the most common of all FPV drone bolt sizes 2.5mm and 2mm hex drivers. This tool is all y
Anti Gravity, I Term Relax, and Tuning Feedforward
Achieving a well-tuned flight experience involves more than just stabilizing P, D, and I gains. You’ll also want to explore Anti Gravity, I Term Relax, and tuning Feedforward. These features shape how your quad responds during throttle changes, stick movements, and fast maneuvers.
- Anti Gravity (AG): Adjust the AG gain to improve stability during rapid throttle changes while avoiding excessive instability or a heavy feel.
- I Term Relax: Activate this feature to reduce slow bounceback during flips and rolls, leading to smoother transitions.
- Feedforward: Use Feedforward to sharpen stick response without relying only on higher P gain.
- Stick Response Slider: Increase this setting to boost your quad’s reaction speed, but be cautious to prevent jitteriness.
- Testing: Always test your settings in a safe environment to find the right balance for your flying style.
Feedforward is especially useful because it helps the quad react to your stick movement before large error builds up. If Feedforward is too low, the quad may feel delayed or soft. If it is too high, it may feel twitchy, jerky, or too sharp around stick movements. Tune it after your basic PID balance feels stable.
Anti Gravity helps during rapid throttle punches and throttle drops. If your quad dips, wobbles, or changes attitude when you punch the throttle, Anti Gravity can help. I Term Relax helps prevent I gain from fighting fast intentional stick moves, which can reduce slow rebound after flips and rolls.
Enabling Dynamic Damping and Tuning Rates and Expo
When you enable Dynamic Damping, you’re improving how your quad handles fast movements and sharp corrections. Dynamic Damping can increase D gain during aggressive movements, improving control when the quad needs it most. After enabling or adjusting it, conduct aggressive flying tests carefully while monitoring motor temperatures to prevent overheating.
Next, start with the default Betaflight Rates, then adjust the RC Rate, rate curve, and expo to control how the quad responds across the stick range. Rates affect maximum angular velocity at full stick deflection, while expo softens or shapes response near center stick. Tailor these settings to match your flying style.
For Pitch and Roll, adjust the rates independently if your quad feels better with different flip or roll speeds. Freestyle pilots often prefer a smooth center with enough full-stick speed for tricks. Racing pilots may prefer sharper response and predictable cornering. Cinematic pilots usually benefit from lower rates, more expo, and smoother stick movement.
Aim for values that feel responsive while maintaining stability at stick extremes. If the drone becomes difficult to control, lower the rates or increase expo. These adjustments refine your experience and make your quad more responsive, predictable, and enjoyable during flight.
Final Adjustments and Other Settings
As you finalize your tuning process, it is crucial to conduct thorough test flights to evaluate your quad’s overall performance. During these flights, document all settings for future reference and make minor adjustments based on specific flight characteristics. Avoid changing several sliders at once, because that makes it harder to know which setting caused the improvement.
Consider these key areas for final tweaks:
- Reassess PID gains to eliminate drift or wobbles, especially during horizontal descents.
- Monitor motor temperatures to prevent overheating after significant PID adjustments.
- Enable or refine Anti Gravity in Betaflight for improved stability during rapid throttle changes.
- Adjust the Stick Response Slider for quicker quad reactions, enhancing your control.
- Revisit gyro filtering settings, particularly low pass filters, to optimize responsiveness while minimizing noise and potential wobble.
- Review Feedforward if the quad feels delayed, twitchy, or inconsistent during stick inputs.
- Check rates and expo if the tune feels stable but the quad still feels too slow or too sensitive.
Your final tune should match your flying style, not someone else’s settings. A racing tune, freestyle tune, cinematic tune, and long-range tune can all feel different while still being correct. The best result is a quad that tracks cleanly, stays cool, resists propwash, and feels natural in your hands.
Frequently Asked Questions
How do you tune PID in Betaflight?
To tune PID in Betaflight, start with a mechanically clean quad and default settings. Tune P gains first for tracking, adjust D gains to control overshoot and bounceback, then refine I gains for drift correction. Make one change at a time, test briefly, and check motor temperatures after each flight.
What is the best PID tuning method?
The best PID tuning method is a gradual, repeatable process. Start from safe defaults, test the quad, adjust one setting at a time, and record the result. Focus on P and D balance first, then tune I gain, Feedforward, Anti Gravity, rates, and expo after the quad feels stable.
What is TPA and TPA breakpoint?
TPA means Throttle PID Attenuation. It reduces PID authority at higher throttle levels to help control high-throttle oscillations. The TPA breakpoint controls where that reduction begins. Use it carefully, because too much attenuation can make the quad feel less locked in at higher throttle.
What is the rule of thumb for PID tuning?
A common rule of thumb is to increase P gain until the quad tracks well but stop before clear oscillation appears. Then adjust D gain to reduce overshoot and bounceback. Keep I gain balanced enough to correct drift without making the quad feel slow or heavy.
How do I know if my D gain is too high?
D gain may be too high if your motors get hot quickly, the quad sounds harsh, or you notice fine vibration after fast moves. Land and let the motors cool. Then lower D gain, add filtering, inspect the props, and check for mechanical noise.
Can I copy PID settings from another drone?
You can use another similar build as a rough reference, but you should not blindly copy its PID settings. Frame stiffness, motor condition, prop choice, battery weight, firmware version, filtering, and build quality all affect the tune. Defaults and small changes are safer.
Conclusion
In the world of Betaflight PID tuning, achieving the perfect flight is like crafting a fine instrument. Just as a violinist adjusts each string for harmony, you’ll refine each setting for a better balance of control, smoothness, and stability. Every careful tweak brings you closer to the sweet spot where responsiveness and confidence work together.
Start with a clean build, use safe defaults, tune one setting at a time, and check your motors often. Focus first on P and D balance, then refine I gain, Anti Gravity, Feedforward, Dynamic Damping, rates, and expo. Document your journey, compare each test flight, and avoid chasing extreme numbers. With patience, your quadcopter will feel more precise, more stable, and more enjoyable every time you fly.
